Mechatronics Cube-Collecting Robot
Project Overview
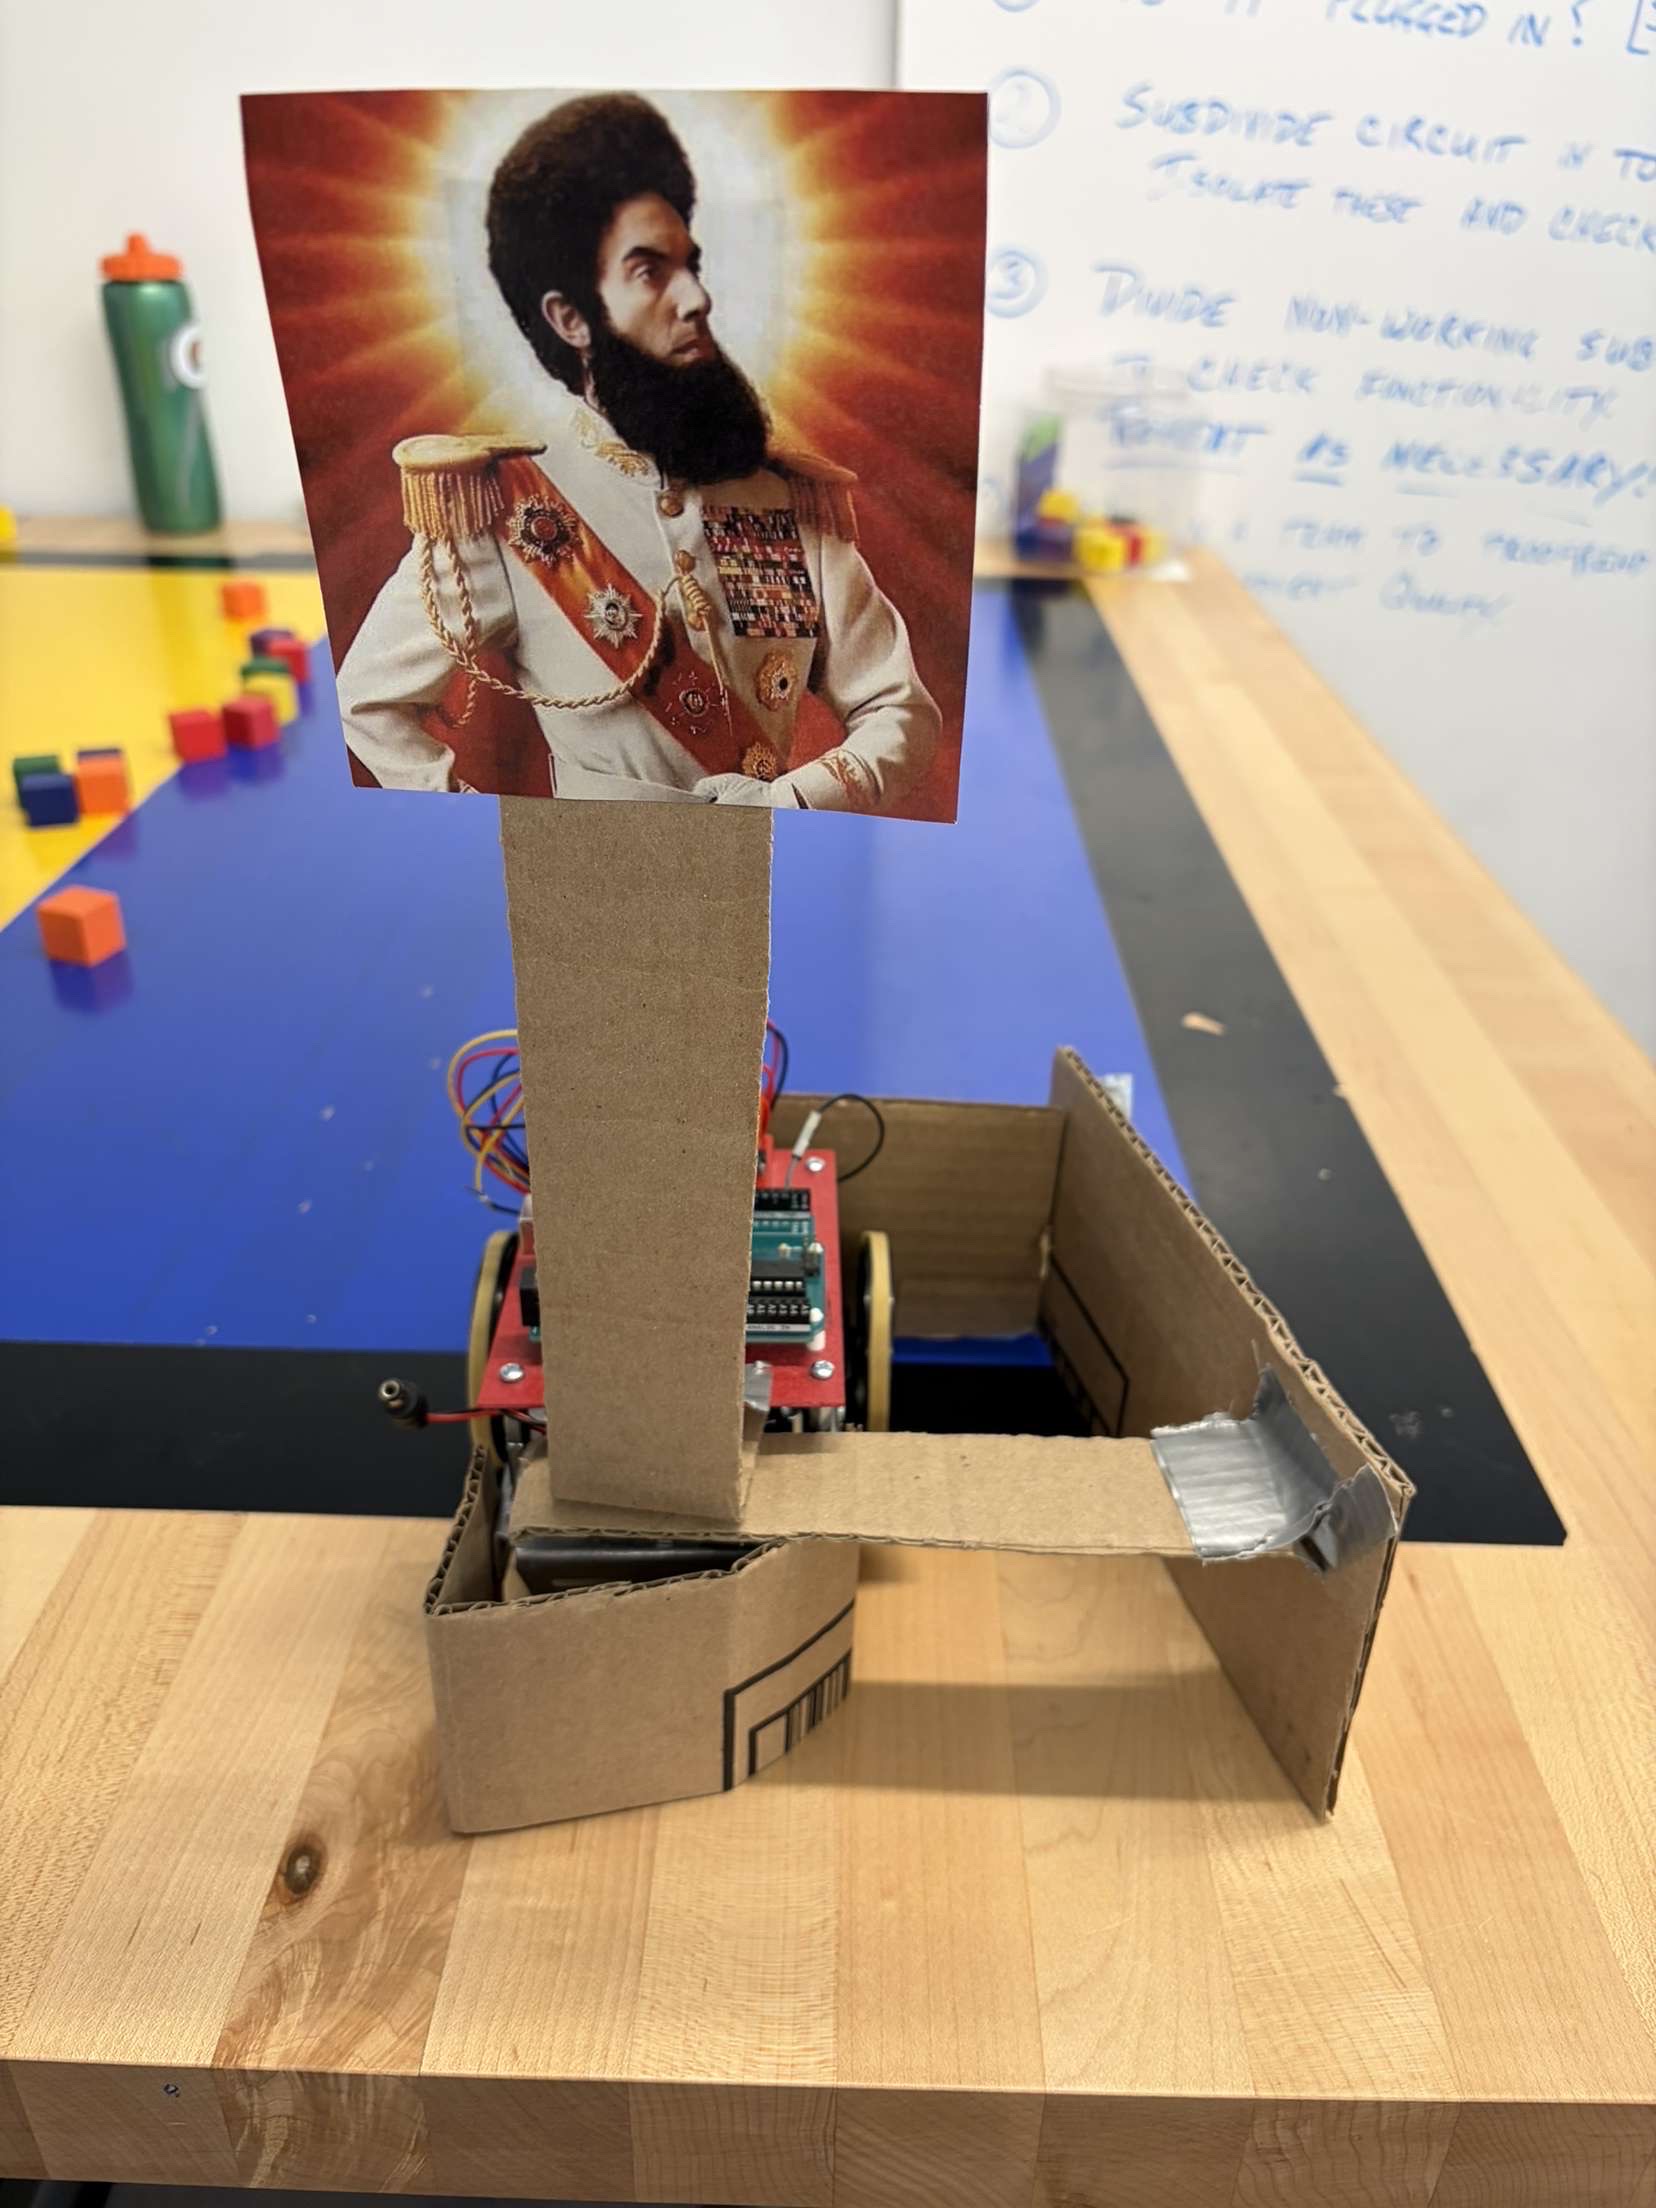
For this mechatronics project, my team designed and built an autonomous robot that competed to collect as many cubes as possible while staying within an initial 8 inch size constraint. Our strategy was to drive quickly toward the center, detect the color change between the yellow and blue field regions, turn right, continue forward, and stop once the black border was detected.
Design Strategy
Rather than attempting to collect every cube on the board, our goal was to reliably collect 11 cubes, which would guarantee a win. The robot used a front cardboard catching mechanism with an 8 inch opening to funnel cubes inward and prevent them from escaping during turns or contact with the opposing robot.
Controls and Sensing
The robot used a color sensor connected to an Arduino-based control system. The code measured pulse periods from the sensor to classify yellow, blue, and black surfaces. To avoid false detections, the robot required the target color or black border to be detected multiple times in a row before changing behavior.
The main control sequence was:
- Detect starting color
- Set the opposite color as the target
- Drive forward until the target color is detected
- Stop and turn right
- Drive forward until black is detected
- Stop permanently
Results
During competition, our robot finished with 3 wins, 2 losses, and 1 tie. The catching mechanism worked well, successfully holding blocks that entered the front opening. The main issue was that the right turn was closer to 120 degrees instead of 90 degrees, which sometimes caused the robot to collide with the opponent or miss the ideal path.
What I Learned
This project helped me understand the importance of testing under realistic final conditions. Small changes, such as new batteries or tightening screws before competition, affected motor speed and changed the robot’s turning behavior. I also learned how valuable simple but reliable design decisions can be, especially when working with sensors, motors, and limited debugging time.
Future Improvements
If I redesigned the robot, I would increase the wheel size to improve speed and use an expanding catching arm after the start of the match. I would also tune the turning delay more carefully under final competition conditions and avoid making mechanical changes immediately before testing.
Open full PDF: Mechatronics Cube-Collecting Robot Final Report
Technologies Used: Mechatronics, Arduino C, Color Sensor, Robot Design
Back to Projects